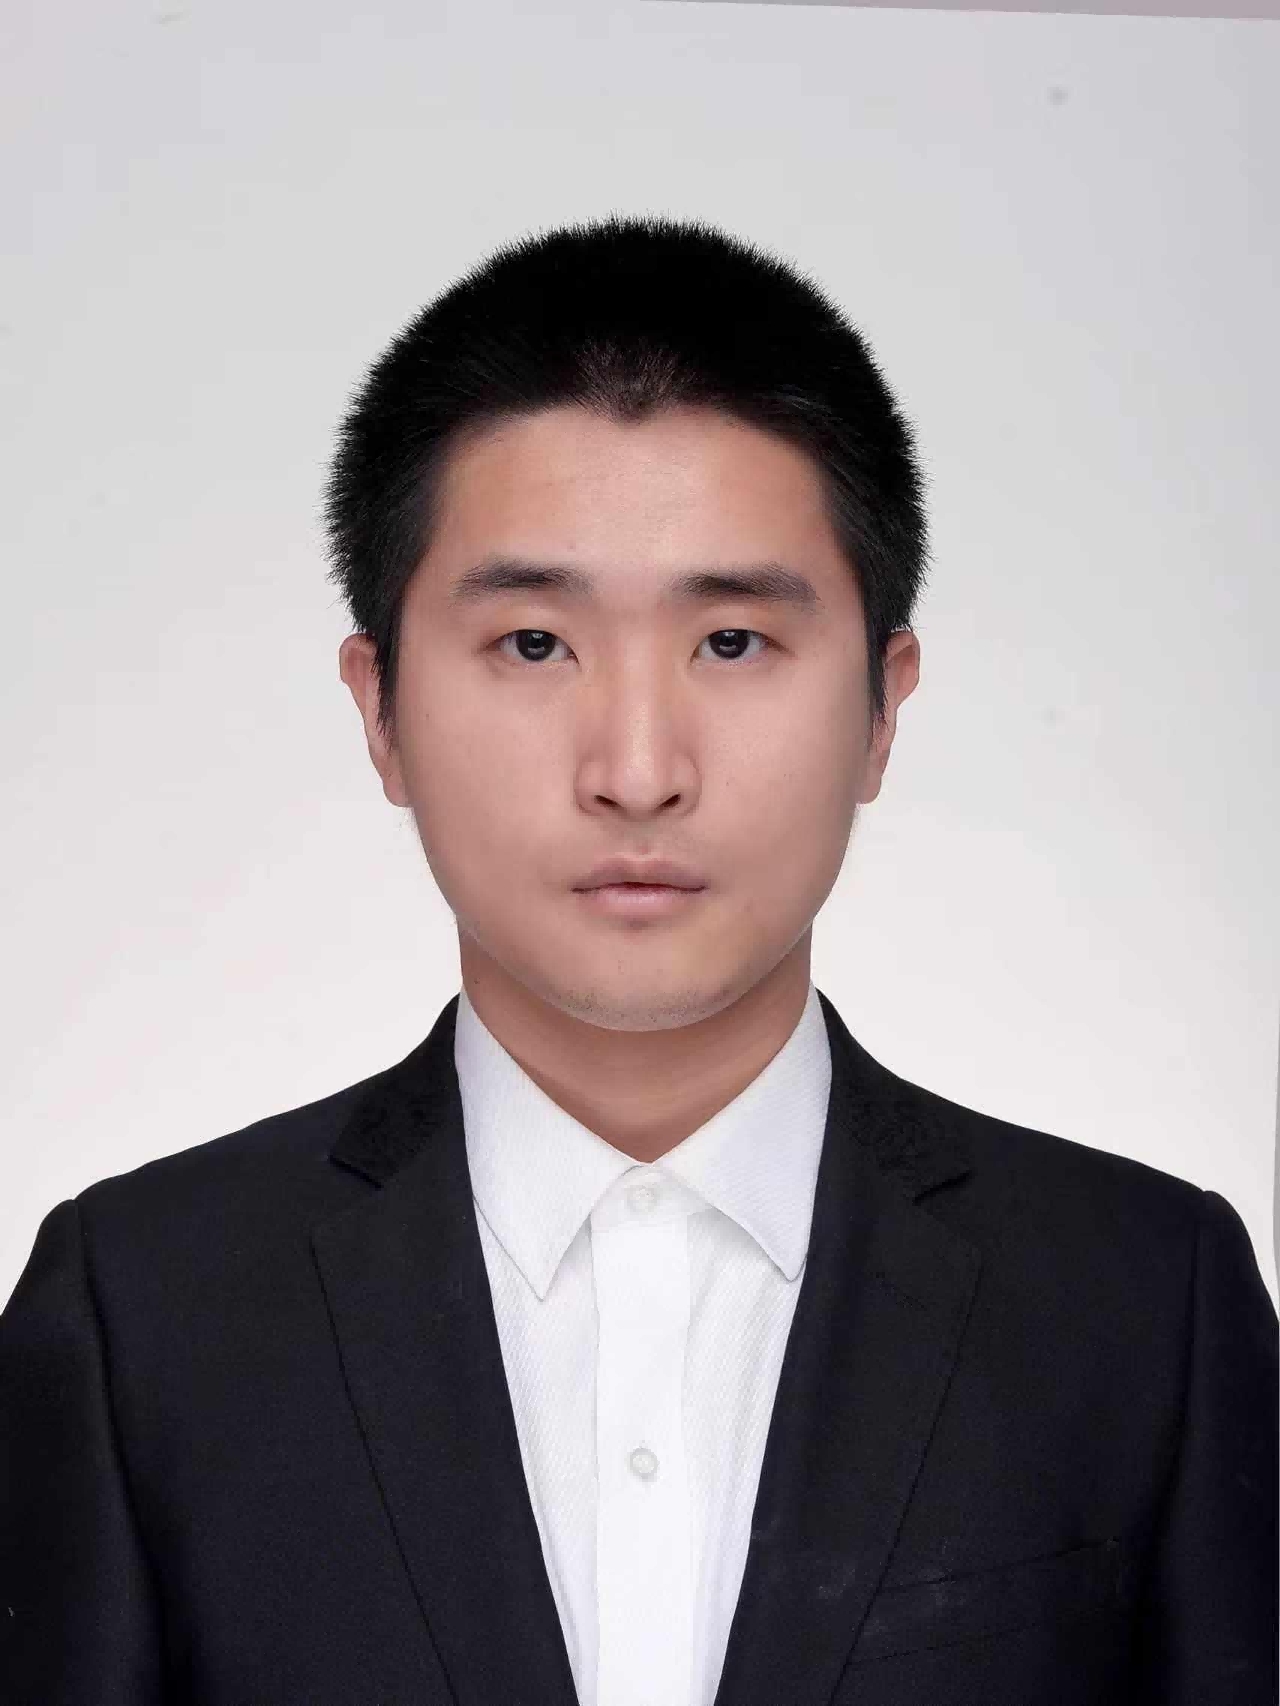
Curriculum Vitae
Education
- Ph.D. student, The University of Hong Kong, Present (Jan. 2026 – Present)
- M.Phil. in Computer and Information Engineering, The Chinese University of Hong Kong Shenzhen, 2025 (Sept. 2023 – Nov. 2025)
- B.Eng. in Electronic Information Engineering, Jilin University, 2023 (Sept. 2019 – June 2023)
Research experience
- Research Intern, Institute of AI China Telecom (TeleAI), 2025
- Developed a dual-autoencoder framework for efficient cross-robot fine-tuning using asymmetric Info-VAEs and a unified cross-embodiment action space.
- Validated RDT policies in RoboTwin/ManiSkill3 and conducted preliminary deployment on a Unitree H1-2 humanoid with a RoboTera dexterous hand.
- Designed a recursive action-averaging strategy for smooth and robust real-world control.
- Developed a sparse-data VLA fine-tuning pipeline combining trajectory/video augmentation with real-world reinforcement learning.
- Graduate Researcher, The Chinese University of Hong Kong Shenzhen, 2023 - 2024
- Built a fully autonomous ultrasound-guided biopsy system using a UR5e arm, ROS, U-Net++, 3D reconstruction, slice-to-volume registration, force/pose control, and reinforcement learning.
- Proposed a robot-assisted quantitative compression elastography framework for accurate elasticity measurement.
Projects
- Development of Data Collection System and Real-World Deployment Experiments on DP3 (Apr. 2025 – May 2025)
Developed data-collection tooling for the RoboTera dexterous hand and Unitree H1-2 humanoid, supported real-world DP3 deployment experiments, and contributed to paper writing. - Action Chunking Transformer Reimplementation and Demonstration at DTEC (Nov. 2024 – Dec. 2024)
Contributed to teleoperation development and ACT/OpenTeleVision reproduction and adaptation; demonstrated the system at the TeleAI Developer Conference. - Spectrum-Sensing Chip for Explosive Detection (Dec. 2022 – May 2023)
Graduation project awarded Excellent Graduation Design by the School of Electronic Science and Engineering, Jilin University. - Vehicle Intelligent-Arm Grasping System Based on Motion Matching (May 2021 – May 2022)
Team leader; awarded Outstanding Provincial Project.
Publications
- Y. Zhang†, C. Wang†, O. Lu†, Y. Zhao, Y. Ge, Z. Sun, X. Li, C. Zhang, C. Bai*, and X. Li*, “Align-Then-stEer: Adapting the Vision-Language Action Models through Unified Latent Guidance,” ICLR, 2026.
- C. Wang†, C. Qian†, Q. Gao, X. Ji, and Z. Sun, “Towards Fully Autonomous Robotic Ultrasound-Guided Biopsy for Superficial Organs,” IEEE/RSJ IROS, 2025.
- C. Wang, Q. Gao, D. Zhang, Z. Wang, and Z. Sun, “Robotic Assistance for Standardized Compression Ultrasound Elastography,” IEEE RCAR, 2024. Best Conference Paper Finalist nominee.
- S. Yang, Y. Zhang, C. Bai, C. Wang, O. Lu, and X. Li, “Enhancing Dexterous Diffusion Policy with Predictive 3D Representations,” under review at IEEE Transactions on Cybernetics. Led the real-world robotic experiments.
† Equal contribution. * Corresponding author.
Awards and experience
- Nominee for the Outstanding Graduate Student Award, The Chinese University of Hong Kong, Shenzhen, 2025
- Top-Performing Intern, Institute of AI, China Telecom (TeleAI), 2025
- Best Conference Paper Finalist nominee, IEEE RCAR, 2024
- Excellent Graduation Design, School of Electronic Science and Engineering, Jilin University
- Digital Technology Ecosystem Conference (DTEC), 2024 — Represented TeleAI and demonstrated embodied-AI and robotic technologies to academic, industry, and developer audiences.
- World Artificial Intelligence Conference (WAIC), 2025 — Supported the preparation and coordination of TeleAI’s exhibition and its on-site technology demonstrations.
- Embodied Intelligence Hub (具身智能之心), 2025 — Presented TeleAI’s robotic research in a livestream, demonstrating real-world embodied-intelligence systems and experimental results.
- Jiqizhixin (机器之心), 2025 — TeleAI’s embodied-AI and robotics work was featured in technical media coverage.